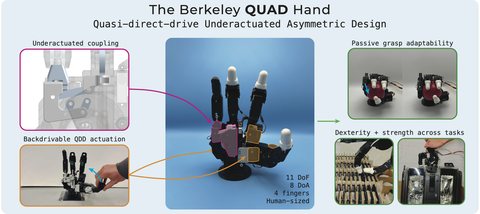
UC Berkeley Berkeley QUAD Hand
Specifications
Record source date: 2026-10-02
Active / total DOF: 8 / 11
Weight basis: Hand-only mass not established in the reviewed source.
Availability / status: September 2026 preprint prototype
Evidence limits: Eight actuators and 11 DOF are distinct. Published grasp demonstrations do not establish general autonomous success. Public finished-product price, mass and delivery unverified.
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-10-02. Links describe a model or family relationship, not hardware-tested compatibility.
Berkeley QUAD Hand research
UC Berkeley · Research use
Author project, mechanism overview and paper.
A project viewer does not establish a downloadable build kit or commercial availability.
Learn to audit a model-to-hand interface →