
Rysen Robotics (源升智能) Apex Hand
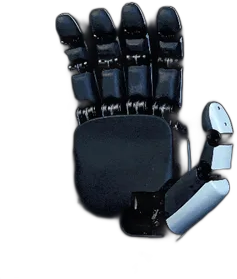
Rysen Robotics (源升智能) Apex Hand is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
Specifications
Record source date: 2026-09-16
Active / total DOF: 16 / 21
Soft e-skin on fingertips, phalanges and palm; absolute joint encoders
Weight basis: Manufacturer hand weight; installation boundary unspecified
Availability / status: Manufacturer listing; delivery unverified
Evidence limits: Fingertip force >20 N; repeatability <0.5 mm. 3 Hz is a grip-cycle claim. Older coverage calls the company Dexcel; current site uses Rysen. Do not count both as separate Apex models.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Apex developer downloads
Rysen Robotics · Model-specific
SDK, ROS 2, Python/C++ and left/right model downloads.
Beta SDK. The publisher page was indexed, but its certificate chain could not be validated during our link check; ask the manufacturer for a current download if needed.
All Hands Up! — Rysen Apex Hand 3D viewer
RLWRLD · Model-specific
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
Verify the modeled revision and joint definitions with the project. Simulation visualization is not a hardware test or device driver.
Rysen Apex Hand · right · model 0.2.0 — original model package
RysenRobotics · Family resource
Original publisher geometry used by the native Dexhands viewer. BSD-3-Clause; pinned source 3f482caadf61c91e71df6be9e33e2122da768637.
Original right-hand model package 0.2.0, a preliminary release. The source has 21 joints, including 5 coupled joints and 16 actuated axes; joint sliders are not a hardware DOF rating. Dynamics are not fully calibrated by the publisher.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Rysen Robotics (源升智能) Apex Hand?
Rysen Robotics (源升智能) Apex Hand is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Rysen Robotics (源升智能) Apex Hand?
Active / total DOF: 16 / 21. Sensing: Soft e-skin on fingertips, phalanges and palm; absolute joint encoders. Weight basis: Manufacturer hand weight; installation boundary unspecified. Availability / status: Manufacturer listing; delivery unverified.
How much does the Rysen Robotics (源升智能) Apex Hand cost?
Public price observations are not established for this record. Use the original source or send a supplier inquiry for current pricing.
Where can I buy or source the Rysen Robotics (源升智能) Apex Hand?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.