
WUJI TECH WUJI Hand Gen1
WUJI TECH WUJI Hand Gen1 is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-15.
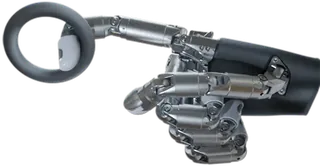
Specifications
Record source date: 2026-09-15
Active / total DOF: 20 / 20
Joint/motor feedback; no integrated tactile stated; optional >400-sensor tactile glove accessory
Weight basis: One Gen1 bare hand: 0.580 ± 0.010 kg; cables, soft parts and glove excluded.
Availability / status: Legacy / archived
Evidence limits: Archived generation; mechanical values retain previous snapshot. Not counted as current-generation commercial SKU.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Wuji SDK
Wuji Technology · Family resource
Manufacturer device discovery, control, streaming and recording tools.
Check Hand 1 / Hand 2 support and required firmware in the current release.
Wuji robot descriptions
Wuji Technology · Family resource
Manufacturer URDF, MJCF, MJX and USD model resources.
Use the model matching your hardware generation.
All Hands Up! — Wuji Hand v1.1 3D viewer
RLWRLD · Family resource
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
Related to the first-generation family; the catalog Gen1 record is not a confirmed v1.1 revision match. Simulation visualization is not a hardware test or device driver.
Wuji Hand · hand/body revision — original robot-description package
wuji-technology · Family resource
Original publisher geometry used in the Dexhands native 3D viewer. MIT; source revision 5c4dfa16917355d073e2e1d7e3d03897b6cf9508.
Visual geometry and joint definitions only. Confirm exact hardware variant; browser rendering is not an SDK integration or physical performance test.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the WUJI TECH WUJI Hand Gen1?
WUJI TECH WUJI Hand Gen1 is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-15.
What are the specifications of the WUJI TECH WUJI Hand Gen1?
Active / total DOF: 20 / 20. Sensing: Joint/motor feedback; no integrated tactile stated; optional >400-sensor tactile glove accessory. Weight basis: One Gen1 bare hand: 0.580 ± 0.010 kg; cables, soft parts and glove excluded.. Availability / status: Legacy / archived.
How much does the WUJI TECH WUJI Hand Gen1 cost?
Public price observations are not established for this record. Use the original source or send a supplier inquiry for current pricing.
Where can I buy or source the WUJI TECH WUJI Hand Gen1?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.