
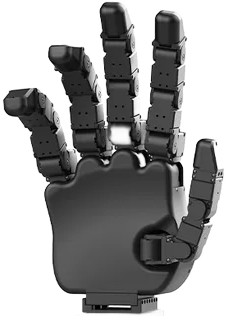
ROBOTIS Hand HX5-D20-MRT (right)
ROBOTIS Hand HX5-D20-MRT (right) is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
Specifications
Record source date: 2026-09-16
Active / total DOF: 20 / 20
9-element fingertip sensor array; raw 0–255 readings
Weight basis: 1,000 g ±2%
Availability / status: Current / marketed
Evidence limits: 1 kHz stated control frequency. Exact low-level control interfaces remain subject to ROS 2 driver finalization.
Price scope: ROBOTIS US official store: USD 7,703.85 for selected left or right HX5-D20 hand
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
ROBOTIS Hand ROS 2
ROBOTIS · Family resource
Official ROS 2 control and sensor integration packages.
Use the HX5 configuration and correct left/right model from the documentation.
All Hands Up! — ROBOTIS HX5-D20 3D viewer
RLWRLD · Family resource
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
Confirm hand side; the viewer does not establish left/right configuration equivalence. Simulation visualization is not a hardware test or device driver.
ROBOTIS HX5-D20 · right · rev2 — original model package
ROBOTIS-GIT · Family resource
Original publisher geometry used by the native Dexhands viewer. Apache-2.0; pinned source 6f9e22a5fc86fe2f0947a44405e52e776c8c08c8.
Original HX5-D20 right rev2 geometry, expanded from the publisher Xacro. Matches the right-hand family, not the left-hand SKU. Red fingertip boxes are source reference markers. Model limits are not validated hardware ratings.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the ROBOTIS Hand HX5-D20-MRT (right)?
ROBOTIS Hand HX5-D20-MRT (right) is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the ROBOTIS Hand HX5-D20-MRT (right)?
Active / total DOF: 20 / 20. Sensing: 9-element fingertip sensor array; raw 0–255 readings. Weight basis: 1,000 g ±2%. Availability / status: Current / marketed.
How much does the ROBOTIS Hand HX5-D20-MRT (right) cost?
Public price observations: ROBOTIS US official store: USD 7,703.85 for selected left or right HX5-D20 hand Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the ROBOTIS Hand HX5-D20-MRT (right)?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.