
Inspire Robots RH56F1
Inspire Robots RH56F1 is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
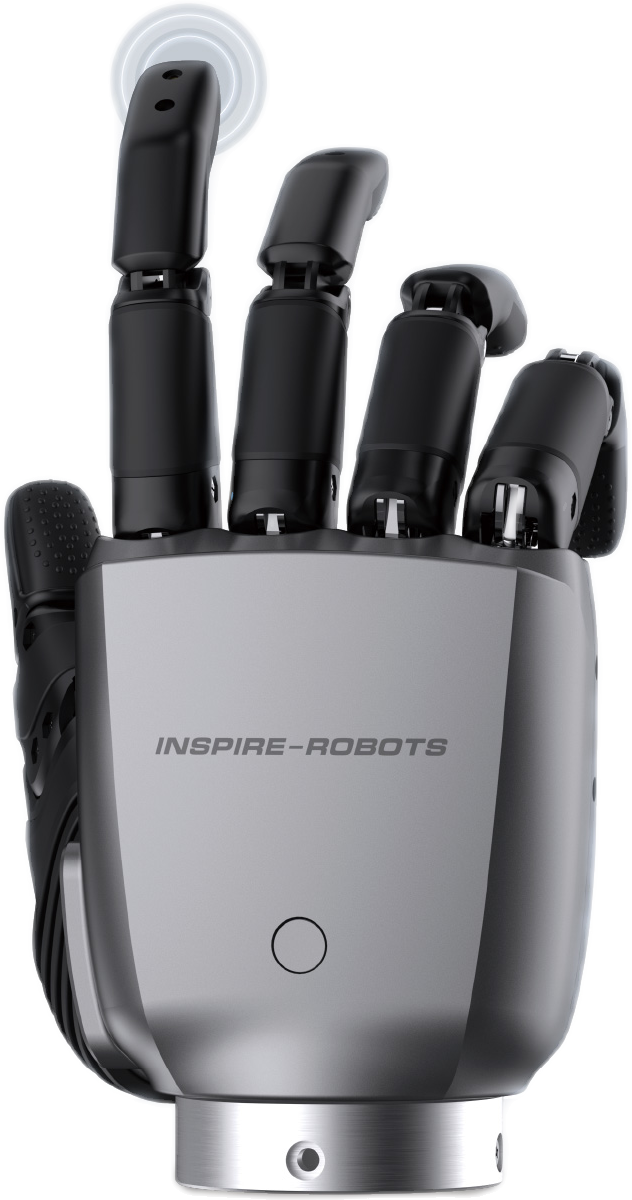
Specifications
Record source date: 2026-09-16
Active / total DOF: 6 / 12
Optional8 tactile modules; position/force feedback
Weight basis: 615±10g base;630±10g tactile
Availability / status: Current / marketed
Evidence limits: Current official masses supersede prior620g family value. Seller bus names differ; confirm exact delivered SKU.
Price scope: USD5,500 base; USD7,500 tactile per hand. Manufacturer current tactile mass630±10g.
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Hand motion retargeting
DexSuite · Family resource
Human-to-robot motion optimizers with configurations for the listed hand families.
Retargeting generates joint targets; it is not a device driver. Verify model geometry and joint order.
Inspire hand research SDK
NYU Robot Learning · Family resource
Research-maintained Python control and kinematics tools for the RH56 family.
Third-party integration, not an Inspire manufacturer SDK. Verify the RS-485 protocol and exact variant.
All Hands Up! — Inspire RH56F1 3D viewer
RLWRLD · Model-specific
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
Confirm side and model revision against the supplied unit. Simulation visualization is not a hardware test or device driver.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Inspire Robots RH56F1?
Inspire Robots RH56F1 is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Inspire Robots RH56F1?
Active / total DOF: 6 / 12. Sensing: Optional8 tactile modules; position/force feedback. Weight basis: 615±10g base;630±10g tactile. Availability / status: Current / marketed.
How much does the Inspire Robots RH56F1 cost?
Public price observations: USD5,500 base; USD7,500 tactile per hand. Manufacturer current tactile mass630±10g. Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the Inspire Robots RH56F1?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.