
RobotEra XHAND1
RobotEra XHAND1 is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
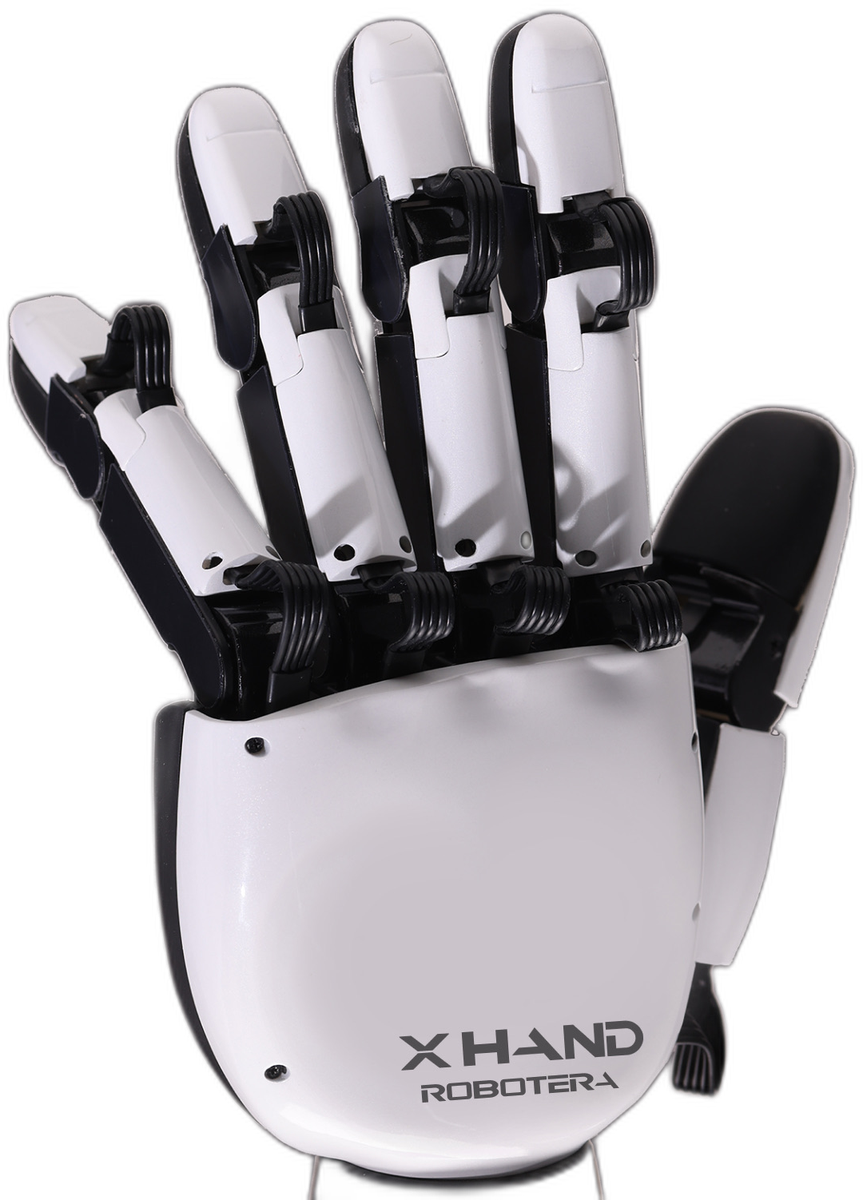
Specifications
Record source date: 2026-09-16
Active / total DOF: 12 / 12
Optional high-resolution tactile sensor per finger, >100points each, providing3Dforce and temperature
Weight basis: hand; maker does not separate optional-sensor mass
Availability / status: Current / marketed
Evidence limits: 15Nfingertip and80Nwhole-hand forces,5kgfingertip/25kgwhole-hand loads are maker claims with incomplete shared test protocol. Tactile option costsUSD16,800 versusUSD13,500base.
Price scope: USD13,500 without tactile; USD16,800 with tactile. One left or right hand; public product variant data checked.
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
XBot hand integration API
RobotEra · Family resource
RobotEra APIs with XHand and XHand Lite control examples.
Requires the RobotEra development environment; this is not a standalone generic hand driver.
XHand1 YARP device
Robotology · Model-specific
Third-party integration connecting XHand1 with YARP.
Requires the vendor SDK and the platform dependencies described by the authors.
All Hands Up! — RobotEra XHAND1 3D viewer
RLWRLD · Model-specific
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
For the XHAND1 reference, not XHAND1 Lite or Pro. Simulation visualization is not a hardware test or device driver.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the RobotEra XHAND1?
RobotEra XHAND1 is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the RobotEra XHAND1?
Active / total DOF: 12 / 12. Sensing: Optional high-resolution tactile sensor per finger, >100points each, providing3Dforce and temperature. Weight basis: hand; maker does not separate optional-sensor mass. Availability / status: Current / marketed.
How much does the RobotEra XHAND1 cost?
Public price observations: USD13,500 without tactile; USD16,800 with tactile. One left or right hand; public product variant data checked. Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the RobotEra XHAND1?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.