
Sharpa Wave / SharpaWave, L/R
Sharpa Wave / SharpaWave, L/R is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
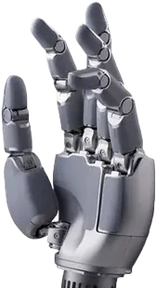
Specifications
Record source date: 2026-09-16
Active / total DOF: 22 / —
DTA fingertip tactile; up to 180 fps; 20 ms latency; configuration-dependent
Weight basis: Hand only; camera and compute excluded.
Availability / status: Current / marketed
Evidence limits: Manufacturer table shows paired 20/12 N fingertip, 150/90 N grip and 40/24 kg payload; extracted labels do not resolve rating/configuration mapping. No single force value assigned.
Price scope: Seller USD 50,000 for one LEFT Wave; tax and freight extra. Revision/accessories need confirmation. The separate RobotLAB USD 78,200 H2 camera/platform package remains in offer history; these are different offers. Manufacturer mass 1.3 kg retained over seller 0.8 kg field.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
ROS 2; MuJoCo and Isaac Sim models; Sharpa Pilot + Wave SDK
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Sharpa Wave SDK
Sharpa · Model-specific
Manufacturer SDK downloads and integration instructions for Sharpa Wave.
Check platform architecture, release and firmware compatibility.
Sharpa Pilot
Sharpa · Model-specific
Device setup, monitoring and firmware-management application.
Follow the manufacturer update procedure and supported release combinations.
Sharpa robot models
Sharpa · Family resource
URDF, USD and XML assets maintained by Sharpa.
Select the Wave model and check the asset-specific license.
Wave hand retargeting
Sharpa · Model-specific
Camera-based hand tracking and retargeting for Sharpa Wave.
Requires Sharpa Wave SDK and the stated capture dependencies.
Sharpa reinforcement learning lab
Sharpa · Family resource
Manufacturer learning examples in Isaac Lab.
Use the provided hardware model and simulator version; this is experimental code.
All Hands Up! — Sharpa Wave 3D viewer
RLWRLD · Model-specific
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
Confirm the modeled revision and sensing configuration separately. Simulation visualization is not a hardware test or device driver.
Sharpa Wave · right — original robot-description package
sharpa-robotics · Model-specific
Original publisher geometry used in the Dexhands native 3D viewer. Apache-2.0; source revision 0d19cac602f46456b819e4b6a2c09a74982c9a3e.
Visual geometry and joint definitions only. Confirm exact hardware variant; browser rendering is not an SDK integration or physical performance test.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Sharpa Wave / SharpaWave, L/R?
Sharpa Wave / SharpaWave, L/R is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Sharpa Wave / SharpaWave, L/R?
Active / total DOF: 22 / —. Sensing: DTA fingertip tactile; up to 180 fps; 20 ms latency; configuration-dependent. Weight basis: Hand only; camera and compute excluded.. Availability / status: Current / marketed.
How much does the Sharpa Wave / SharpaWave, L/R cost?
Public price observations: Seller USD 50,000 for one LEFT Wave; tax and freight extra. Revision/accessories need confirmation. The separate RobotLAB USD 78,200 H2 camera/platform package remains in offer history; these are different offers. Manufacturer mass 1.3 kg retained over seller 0.8 kg field. Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the Sharpa Wave / SharpaWave, L/R?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.