
Barrett Technology BarrettHand BH8-282
Barrett Technology BarrettHand BH8-282 is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
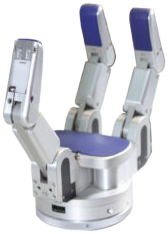
Specifications
Record source date: 2026-09-16
Active / total DOF: 4 / 8
High-precision position encoders; optional fingertip torque, fingertip/palm tactile, 6-axis F/T, or perception palm
Weight basis: Self-contained hand; external 0.7 kg AC supply excluded
Availability / status: Current / marketed
Evidence limits: Four motors control eight axes through underactuation; optional sensors priced separately unless confirmed.
Price scope: EUR38,000 excluding VAT; seller listing; exact sensing package and shipping require confirmation
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Human-to-robot hand embodiment
DFKI Robotics Innovation Center · Research use
Research code for transferring human motions to several supported robot hands.
Use the project’s specific model, calibration and motion-capture assumptions; mesh licenses vary.
libbarrett
Barrett Technology · Model-specific
Manufacturer C++ library with BarrettHand interfaces.
Follow the supported hardware, CAN interface and operating-system requirements.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Barrett Technology BarrettHand BH8-282?
Barrett Technology BarrettHand BH8-282 is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Barrett Technology BarrettHand BH8-282?
Active / total DOF: 4 / 8. Sensing: High-precision position encoders; optional fingertip torque, fingertip/palm tactile, 6-axis F/T, or perception palm. Weight basis: Self-contained hand; external 0.7 kg AC supply excluded. Availability / status: Current / marketed.
How much does the Barrett Technology BarrettHand BH8-282 cost?
Public price observations: EUR38,000 excluding VAT; seller listing; exact sensing package and shipping require confirmation Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the Barrett Technology BarrettHand BH8-282?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.