
PSYONIC Ability Hand for robotics — Large, L/R
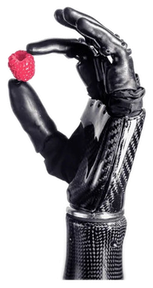
The robotics version of PSYONIC’s Ability Hand exposes control and feedback through a public API. Its robotics page describes six motors and touch-sensor streaming. Record source date: 2026-09-16.
Understand this hand
The robotics version of PSYONIC’s Ability Hand exposes control and feedback through a public API. Its robotics page describes six motors and touch-sensor streaming.
- What distinguishes it
- This record represents the Large variant. The robotics documentation is the relevant starting point; a prosthetics description is not an integration specification.
- Before you build
- Confirm the hand size, connection method, power requirements and command mode against the supplied unit. Use the API’s actual signal definitions for data collection.
Specifications
Record source date: 2026-09-16
Active / total DOF: 6 / —
30 force-sensitive resistors (6/digit); 6 encoders
Weight basis: Large hand; external power system not included in hand mass
Availability / status: Current / marketed
Evidence limits: USD15,000 is a seller family listing, not a manufacturer quote for this size. Structural axial load is not payload.
Price scope: Prior seller family listing USD 15,000 (2026-09-16) could not be revalidated in the 2026-09-17 offer review. Size/side/robotics package unconfirmed; retained as historical evidence only.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Hand motion retargeting
DexSuite · Family resource
Human-to-robot motion optimizers with configurations for the listed hand families.
Retargeting generates joint targets; it is not a device driver. Verify model geometry and joint order.
Ability Hand API
PSYONIC · Family resource
Manufacturer API examples and integration resources for Ability Hand.
Check hand size, communication protocol and firmware; the listing covers both size records.
All Hands Up! — PSYONIC Ability Hand 3D viewer
RLWRLD · Family resource
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
The viewer does not establish size-specific or left/right compatibility. Simulation visualization is not a hardware test or device driver.
PSYONIC Ability Hand · right large — original robot-description package
psyonicinc · Family resource
Original publisher geometry used in the Dexhands native 3D viewer. MIT; source revision 34c9a9324d3739d976e6de441e56ccefafd0000b.
Visual geometry and joint definitions only. Confirm exact hardware variant; browser rendering is not an SDK integration or physical performance test.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the PSYONIC Ability Hand for robotics — Large, L/R?
PSYONIC Ability Hand for robotics — Large, L/R is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16. The robotics version of PSYONIC’s Ability Hand exposes control and feedback through a public API. Its robotics page describes six motors and touch-sensor streaming.
What are the specifications of the PSYONIC Ability Hand for robotics — Large, L/R?
Active / total DOF: 6 / —. Sensing: 30 force-sensitive resistors (6/digit); 6 encoders. Weight basis: Large hand; external power system not included in hand mass. Availability / status: Current / marketed.
How much does the PSYONIC Ability Hand for robotics — Large, L/R cost?
Public price observations: Prior seller family listing USD 15,000 (2026-09-16) could not be revalidated in the 2026-09-17 offer review. Size/side/robotics package unconfirmed; retained as historical evidence only. Confirm current pricing with the manufacturer or a supplier.
Where can I buy or source the PSYONIC Ability Hand for robotics — Large, L/R?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.