
Wonik Robotics Allegro Hand V5 Plus
Wonik Robotics Allegro Hand V5 Plus is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
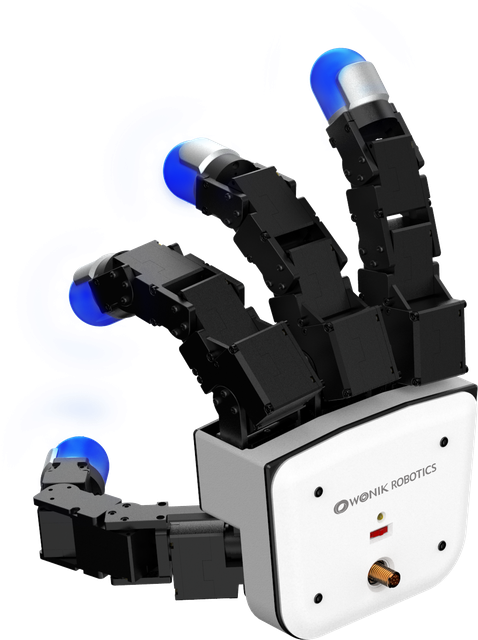
Specifications
Record source date: 2026-09-16
Active / total DOF: 16 / 16
Joint position plus 360° pneumatic/capacitive fingertip pressure sensors
Weight basis: Manufacturer total hand weight
Availability / status: Current / marketed
Evidence limits: Manufacturer payload and joint stall torque depend on grasp, test method and operating conditions; not continuous fingertip force.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Allegro Hand UXD graphical monitoring and motion control; MoveIt shown
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Allegro v5 ROS 2 driver
Wonik Robotics · Family resource
ROS 2 integration for the Allegro v5 family.
Confirm Plus / Sense sensor support and firmware with the manufacturer.
All Hands Up! — Wonik Allegro V5 Plus 3D viewer
RLWRLD · Model-specific
External browser viewer with joint controls, pose presets and simulated thumb-reach visualization.
For V5 Plus, not V5 or V5 Sense. Simulation visualization is not a hardware test or device driver.
Allegro Hand v5 · right A — original robot-description package
Wonikrobotics-git · Family resource
Original publisher geometry used in the Dexhands native 3D viewer. BSD-2-Clause; source revision 80bd4a88d2c59b8ad0242ec3730302bde61c84fb.
Visual geometry and joint definitions only. Confirm exact hardware variant; browser rendering is not an SDK integration or physical performance test.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Wonik Robotics Allegro Hand V5 Plus?
Wonik Robotics Allegro Hand V5 Plus is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Wonik Robotics Allegro Hand V5 Plus?
Active / total DOF: 16 / 16. Sensing: Joint position plus 360° pneumatic/capacitive fingertip pressure sensors. Weight basis: Manufacturer total hand weight. Availability / status: Current / marketed.
How much does the Wonik Robotics Allegro Hand V5 Plus cost?
Public price observations are not established for this record. Use the original source or send a supplier inquiry for current pricing.
Where can I buy or source the Wonik Robotics Allegro Hand V5 Plus?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.