
Shadow Robot DEX-EE
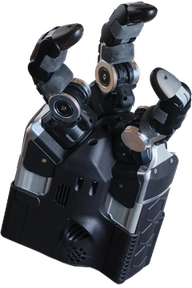
Shadow Robot DEX-EE is a dexterous robotic hand recorded in the Dexhands directory. Original sources and specifications are listed on this page. Record source date: 2026-09-16.
Evidence review · 2026-09-25
Manufacturer, author and seller statements checked against public sources. This is not an independent hardware test. Fields outside this review retain their earlier evidence dates.
- Model / DOF
- Distinct symmetric and Chiral models; page lists 12 DOF per model. Source ↗
- Weight
- 4.1 kg per robot assembly, not a pair; accessory scope needs confirmation. Source ↗
- Sensing / software
- Optical fingertip sensing and ROS integration stated by manufacturer; hardware operation not tested. Source ↗
- Price / availability
- Manufacturer says available to purchase; quote and current lead time required. Source ↗
Specifications
Record source date: 2026-09-16
Active / total DOF: 12 / 12
Per finger: 4 joint positions, 5 tendon forces, motor current/velocity/temperature/clutch, 3-axis accelerometer + gyro; distal optical tactile stereo video; optional Hall tactile arrays on middle/proximal phalanges
Weight basis: One complete three-finger hand, 4.1 kg; not a pair.
Availability / status: Current / marketed
Evidence limits: Historical research lead. Confirm the exact revision and primary-source specification.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
DEX-EE ROS interfaces
Shadow Robot · Model-specific
ROS messages, services and robot descriptions for DEX-EE.
Use the DEX-EE configuration; this is separate from the five-finger Shadow Hand stack.
DEX-EE in MuJoCo
Google DeepMind · Model-specific
DEX-EE model in the MuJoCo Menagerie collection.
Model files and their licenses are maintained in this specific directory.
Shadow DEX-EE configuration 1 — MagTac fingertips — original model package
shadow-robot · Family resource
Original publisher geometry used by the native viewer. BSD-3-Clause; source bd4c293109250f9ed0969d11a89193e450b4cdaa.
Original manufacturer visual geometry and expanded default URDF; illustrative kinematics only. DEX-EE configuration 1 with MagTac fingertips; not configuration 2 or Sparkle version. Catalog H005 is a family association.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Shadow Robot DEX-EE?
Shadow Robot DEX-EE is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16.
What are the specifications of the Shadow Robot DEX-EE?
Active / total DOF: 12 / 12. Sensing: Per finger: 4 joint positions, 5 tendon forces, motor current/velocity/temperature/clutch, 3-axis accelerometer + gyro; distal optical tactile stereo video; optional Hall tactile arrays on middle/proximal phalanges. Weight basis: One complete three-finger hand, 4.1 kg; not a pair.. Availability / status: Current / marketed.
How much does the Shadow Robot DEX-EE cost?
Public price observations are not established for this record. Use the original source or send a supplier inquiry for current pricing.
Where can I buy or source the Shadow Robot DEX-EE?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.