
Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R
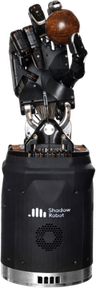
Shadow’s full Dexterous Hand is a five-finger tendon-driven research system. Its manufacturer distinguishes 20 actuated DOF from 24 total joints and offers tactile configurations. Record source date: 2026-09-16.
Understand this hand
Shadow’s full Dexterous Hand is a five-finger tendon-driven research system. Its manufacturer distinguishes 20 actuated DOF from 24 total joints and offers tactile configurations.
- What distinguishes it
- The full hand and the Lite variants differ in fingers, actuators and overall assembly mass. Select the exact configuration before comparing hardware.
- Before you build
- Confirm supplied tactile options, wrist and forearm scope, and the software release. Keep the overall assembly weight distinct from any hand-only figure.
Evidence review · 2026-09-25
Manufacturer, author and seller statements checked against public sources. This is not an independent hardware test. Fields outside this review retain their earlier evidence dates.
- Model / DOF
- 20 actuated axes, 24 joints, 5 fingers; series comparison checked. Source ↗
- Weight
- 4.3 kg overall assembly; isolated hand mass unreported. Excluded from hand-only mass sorting. Source ↗
- Sensing / software
- STF configuration and ROS are manufacturer-reported; installed options and supported releases need confirmation. Source ↗
- Price / availability
- Quote route; no numeric manufacturer price on this page. Stock and lead time unverified. Source ↗
Specifications
Record source date: 2026-09-16
Active / total DOF: 20 / 24
Joint position; 40 tendon-load sensors; 1 IMU; 2 standard / up to 5 Shadow Tactile Fingertips (STF)
Weight basis: 4.3 kg for one hand + forearm. Hand-only weight is not separately disclosed.
Availability / status: Current / marketed
Evidence limits: 24 joints include 2 wrist joints and coupled motion; 20 active DoF. 4.3 kg is overall assembly, not isolated palm.
Explore the hand. Right here.
Rotate, zoom and adjust individual model joints. Downloads begin when you choose Load 3D model. This is geometry, not a physical performance test.
Open larger view ↗ · 27 licensed models available
Software, projects & datasets
What is ready to build with?
Manufacturer lists ROS integration; release compatibility not tested.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
No independent hardware performance or SDK integration test is recorded here. Browser model previews show geometry only.
Curated public references, checked 2026-10-25. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Hand motion retargeting
DexSuite · Family resource
Human-to-robot motion optimizers with configurations for the listed hand families.
Retargeting generates joint targets; it is not a device driver. Verify model geometry and joint order.
Shadow Hand ROS interface
Shadow Robot · Family resource
Manufacturer control interfaces and integration examples.
Select the matching hand configuration and ROS branch; Lite variants have different joints.
Shadow robot descriptions
Shadow Robot · Family resource
URDF descriptions and common packages for Shadow hardware.
Check joint count, hand side and hardware revision before using a model.
Shadow Hand in MuJoCo
Google DeepMind · Model-specific
Simulation assets for the E3M5 Shadow Hand, with left and right versions.
A simulation model, not a hardware driver. Match the E3M5 geometry to your unit.
DexGraspNet
PKU EPIC · Research use
Synthetic grasp data and generation code using a Shadow Hand model.
Simulation-generated grasps are not validated hardware executions.
UniDexGrasp
PKU EPIC · Research use
Vision-based dexterous grasp learning with Shadow Hand simulation tasks.
Follow the authors’ environment and model versions; deployment requires additional work.
Human-to-robot hand embodiment
DFKI Robotics Innovation Center · Research use
Research code for transferring human motions to several supported robot hands.
Use the project’s specific model, calibration and motion-capture assumptions; mesh licenses vary.
DexLearn grasp-synthesis baselines
DexLearn contributors · Research use
Learning-based grasp synthesis with documented Shadow-hand configurations.
Research model association only, not a verified driver for a current Shadow hardware revision. The README states noncommercial terms.
AffordDex: task-appropriate grasp contacts
AffordDex research team · Research use
Affordance-aware policy learning with released Shadow-hand simulation tasks.
Simulation research use; hardware support and reuse permissions must be checked separately.
Shadow Hand E3M5 right — PST fingertips — original model package
shadow-robot · Family resource
Original publisher geometry used by the native viewer. BSD-3-Clause; source 172c3d9c3715ee75eb10dfe4ee57e26a342b4529.
Original manufacturer visual geometry and expanded default URDF; illustrative kinematics only. Right Hand E3M5 with PST fingertips. Catalog H001 is a family association, not exact current unit equivalence. Twenty-four model joint coordinates are not 24 independent actuators; tendon coupling is not implemented by the independent sliders.
Learn to audit a model-to-hand interface →
Frequently asked questions
What is the Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R?
Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R is a dexterous robotic hand record in the Dexhands directory. Record source date: 2026-09-16. Shadow’s full Dexterous Hand is a five-finger tendon-driven research system. Its manufacturer distinguishes 20 actuated DOF from 24 total joints and offers tactile configurations.
What are the specifications of the Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R?
Active / total DOF: 20 / 24. Sensing: Joint position; 40 tendon-load sensors; 1 IMU; 2 standard / up to 5 Shadow Tactile Fingertips (STF). Weight basis: 4.3 kg for one hand + forearm. Hand-only weight is not separately disclosed.. Availability / status: Current / marketed.
How much does the Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R cost?
Public price observations are not established for this record. Use the original source or send a supplier inquiry for current pricing.
Where can I buy or source the Shadow Robot Dexterous Hand Series — Dexterous Hand, L/R?
Check the original source links on this page, or use the Dexhands sourcing page to send one request to multiple suppliers.